Embodied Navigation and Reasoning
Agentic navigation, instruction decomposition, action alignment, and memory-efficient streaming navigation (AgentVLN, IDEAL-VLN, DecoVLN/DecoVLN++), extending to robot manipulation and VLA agents (EmbodiedSkills).
Computer Vision · Embodied AI
I am an Associate Professor in the College of Artificial Intelligence at Nanjing University of Aeronautics and Astronautics, working closely with Prof. Jie Qin. In August 2025 and August 2026, I was a visiting researcher in the Department of Computing at The Hong Kong Polytechnic University, where I collaborated closely with my Ph.D. advisor, Prof. Lei Zhang (IEEE Fellow). Previously, I completed my Ph.D. in the College of Computer Science and Technology at Zhejiang University, supervised by Prof. Jianke Zhu and Prof. Lei Zhang, in June 2024. I have also conducted research at Alibaba DAMO Academy and Ant Group.
I serve as an Area Chair for top-tier AI conferences, including CVPR 2027, ICLR 2026 and 2027, NeurIPS 2026, and AAAI 2027.
I develop embodied AI agents that connect visual perception, reasoning, and action. My research centers on agents that interpret instructions, reason over streaming visual observations, and plan and act continuously with efficient visual and memory representations.
Agentic navigation, instruction decomposition, action alignment, and memory-efficient streaming navigation (AgentVLN, IDEAL-VLN, DecoVLN/DecoVLN++), extending to robot manipulation and VLA agents (EmbodiedSkills).
Visual grounding, video temporal grounding, spatio-temporal object understanding, and efficient visual token representations (Osprey, VideoRefer, PixelRefer, InstructSAM, TokenPacker, VisionTrim).
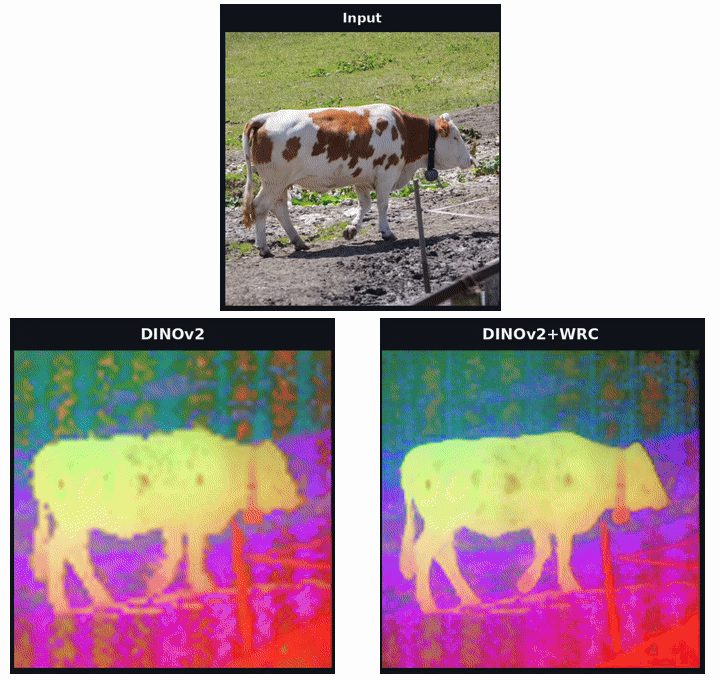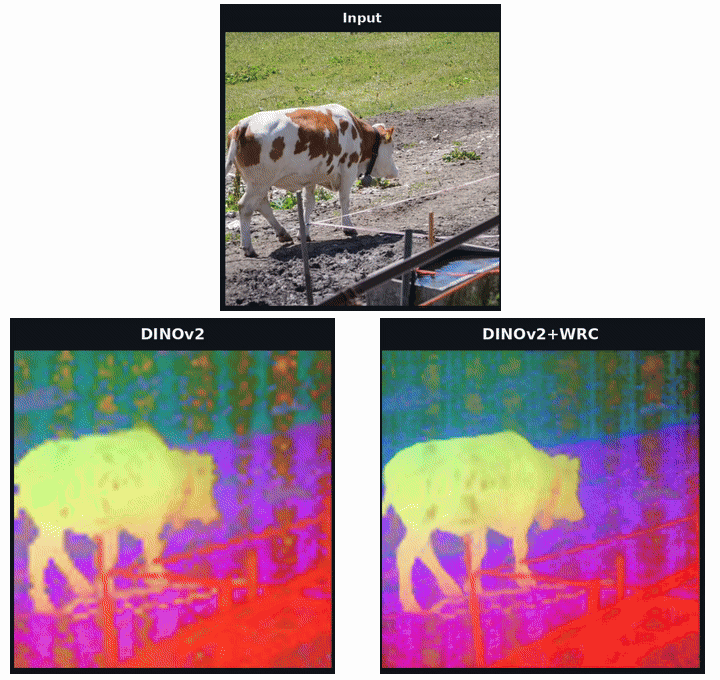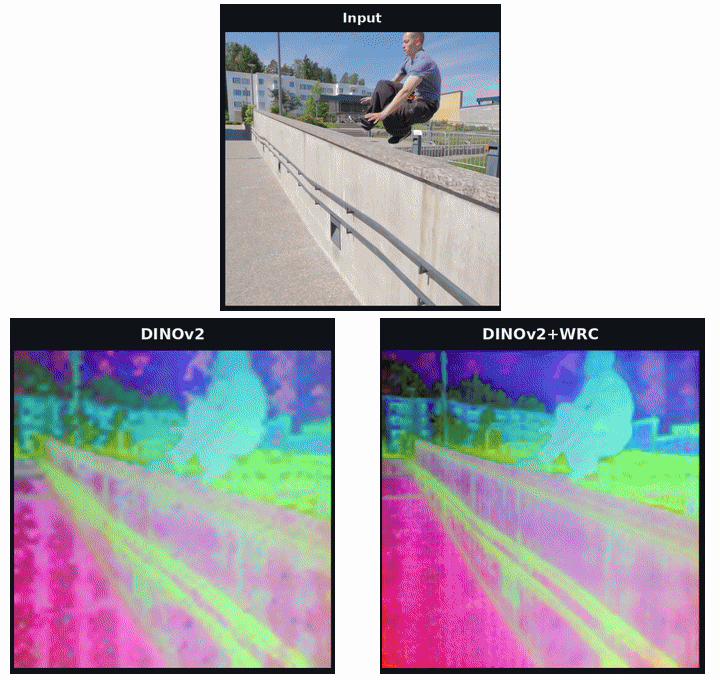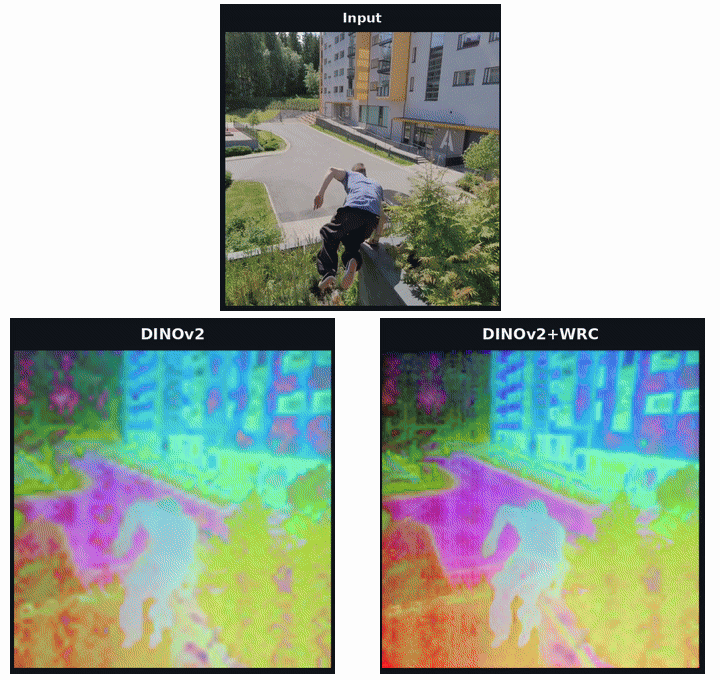
Dense visual representations, latent world modeling, feature upsampling, and segmentation with sparse supervision (WRC, OrientedRepPoints, Box2Mask, Point2Mask, Box2Levelset).
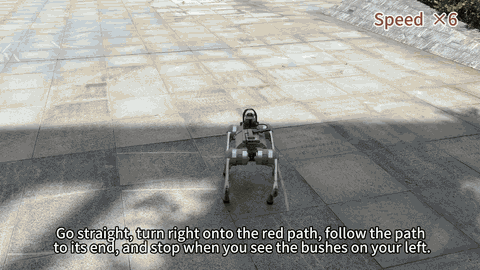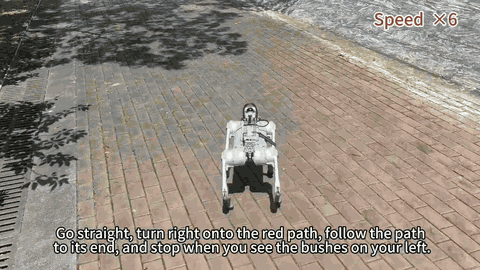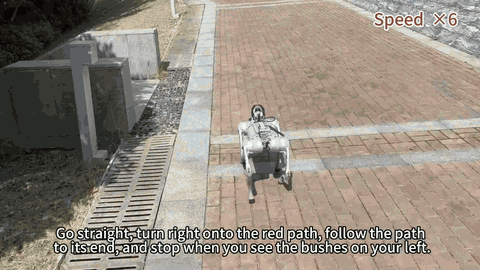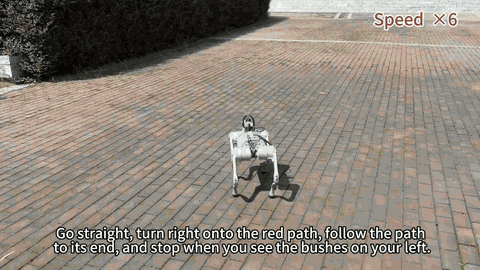 GeoScaffoldEfficient vision-language navigation
 AgentVLNAgentic vision-and-language navigation
 IDEAL-VLNInstruction decomposition and action alignment
 DecoVLNObservation, reasoning, and correction for navigation
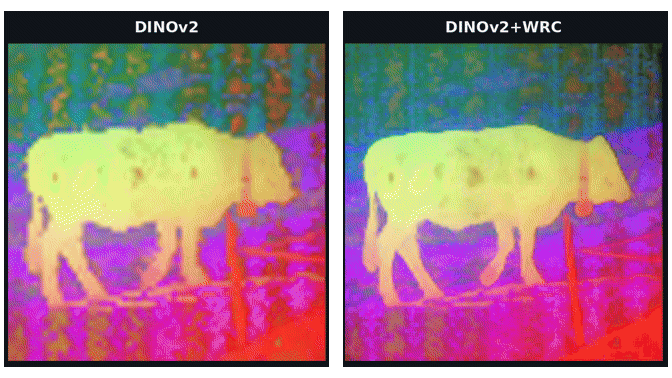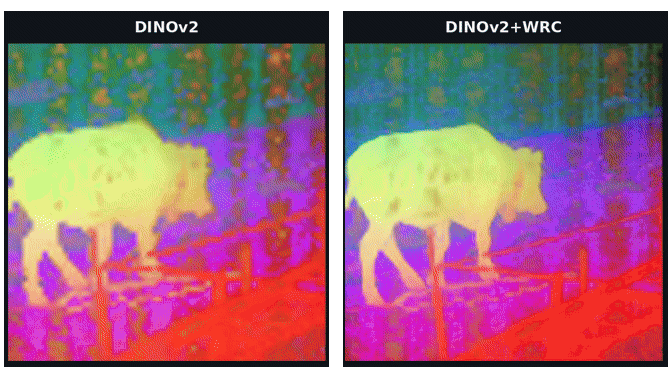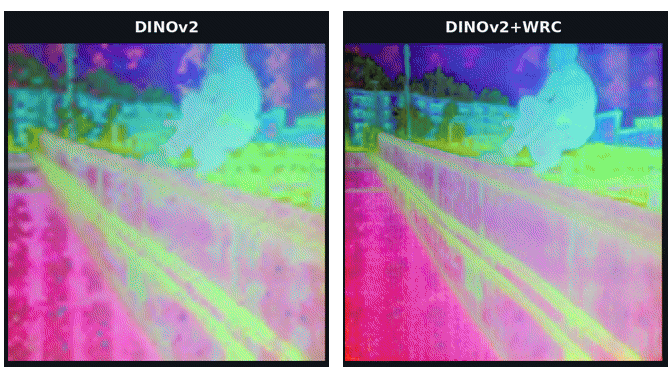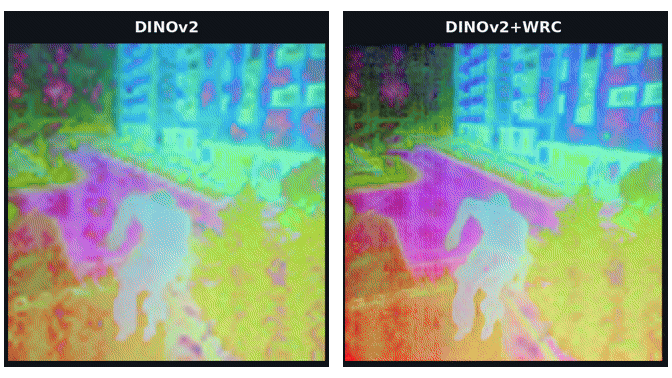 WRCWeighted reverse convolution for feature upsampling
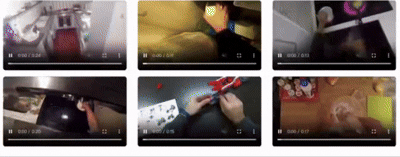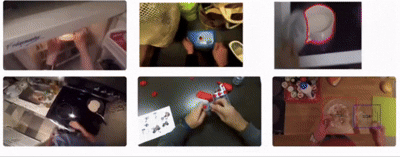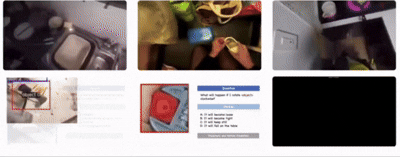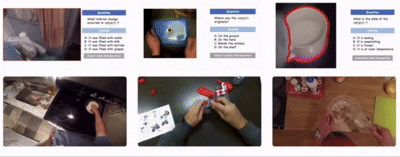 EOC-BenchEgocentric object understanding benchmark
 OspreyPixel understanding with visual instruction tuning
Open positions. I am looking for self-motivated Master's students, research interns/assistants, and co-supervised Ph.D. students. Please email me if you are interested.
*: equal contribution, #: corresponding author, +: project leader

Paper |
Code 


Project Page |
Paper |
Code 

Project Page |
Paper |
Code 
Project Page |
Paper |
Code 


Paper |
Project Page |
Code 

Paper |
ArXiv |
Code


Paper |
Code


Paper |
Code


 |


 |
